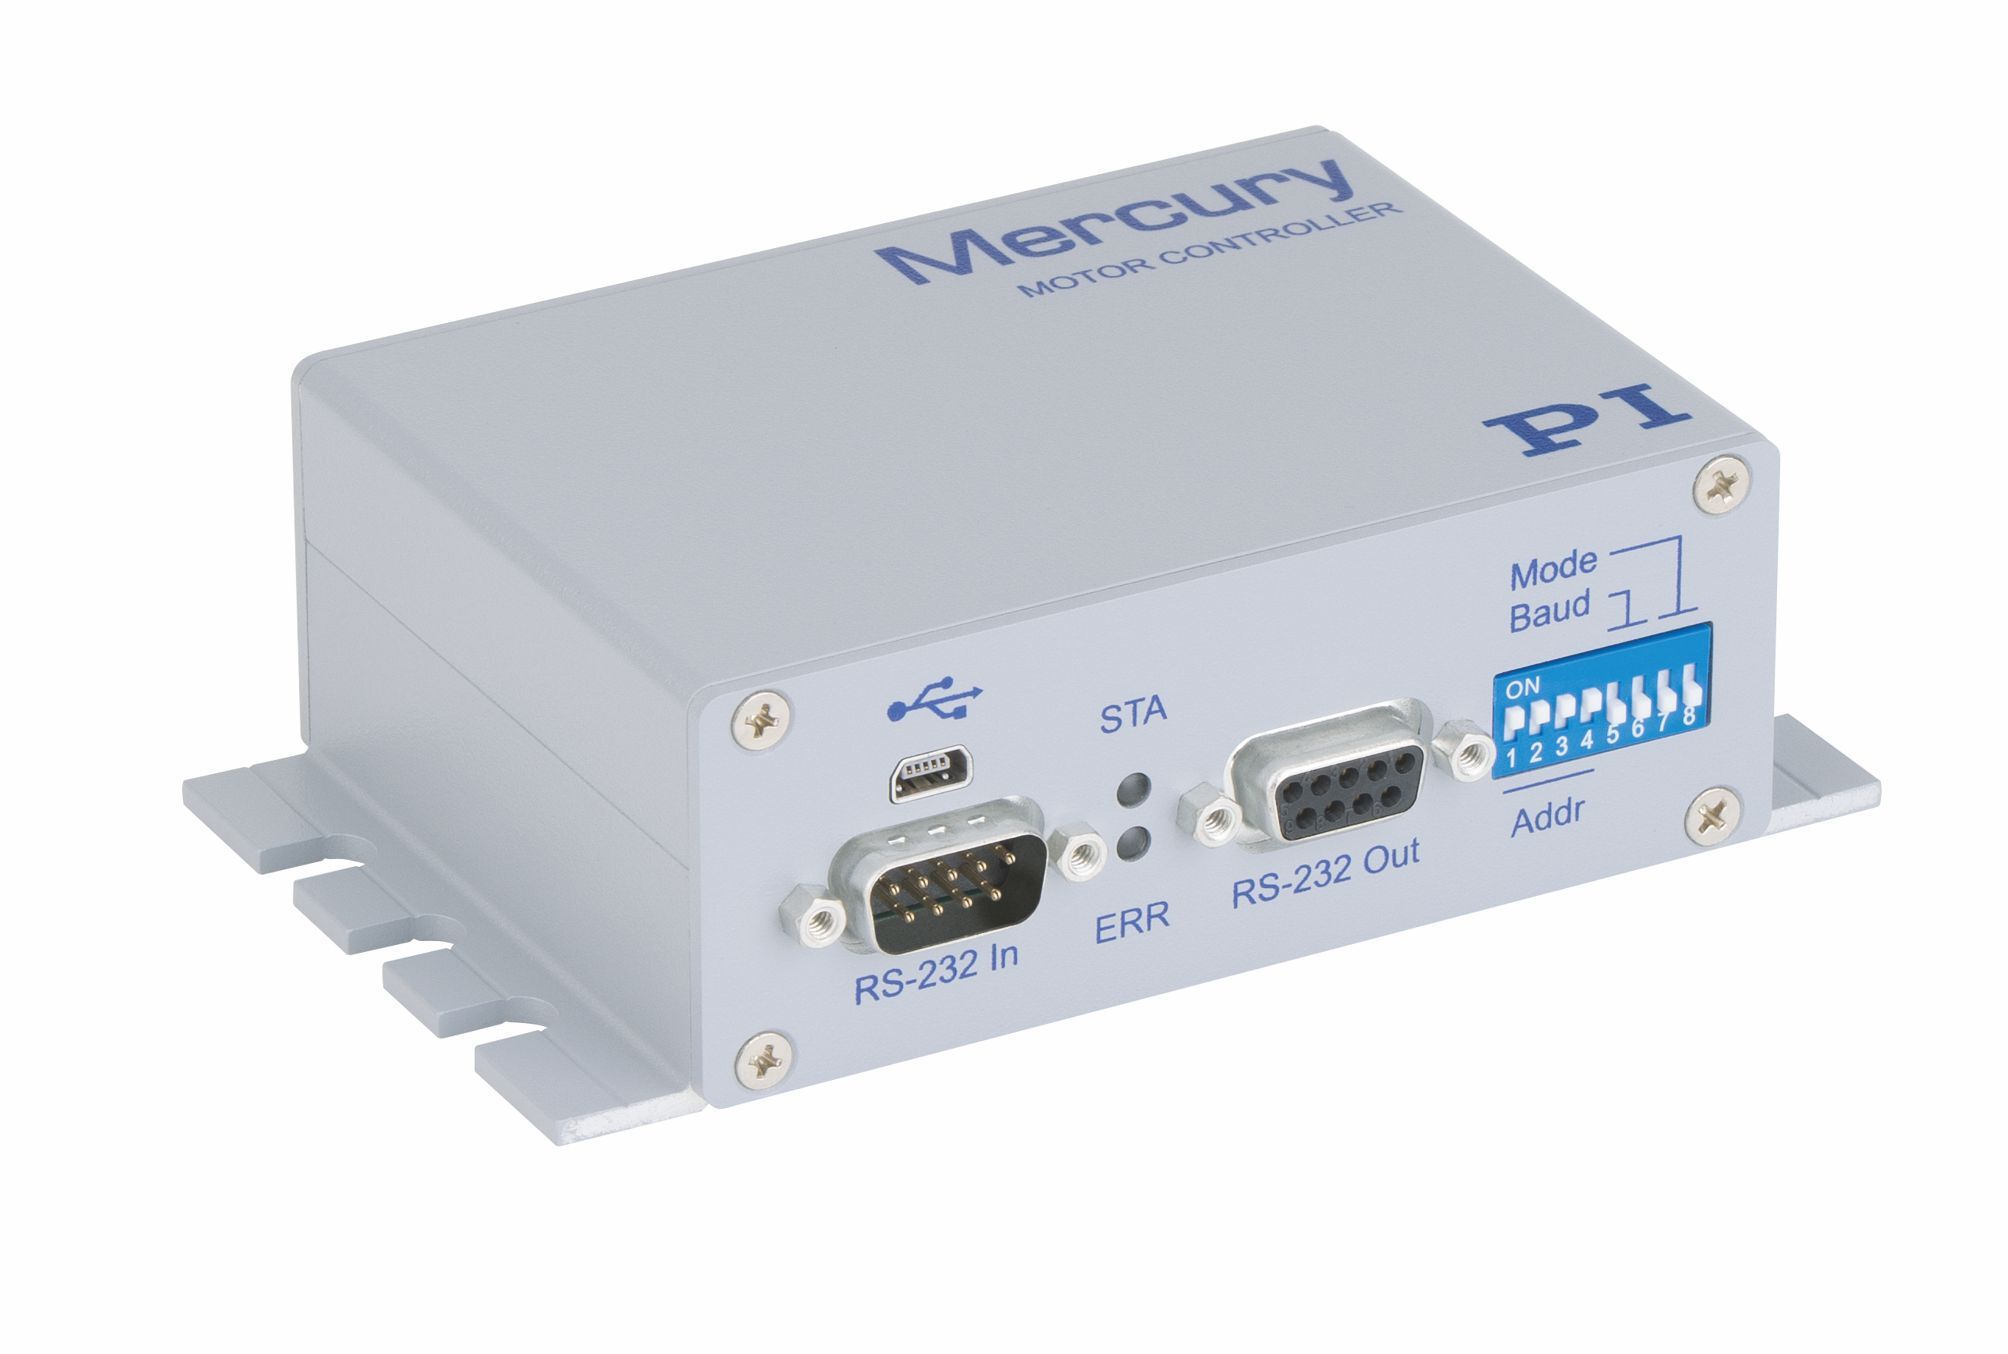
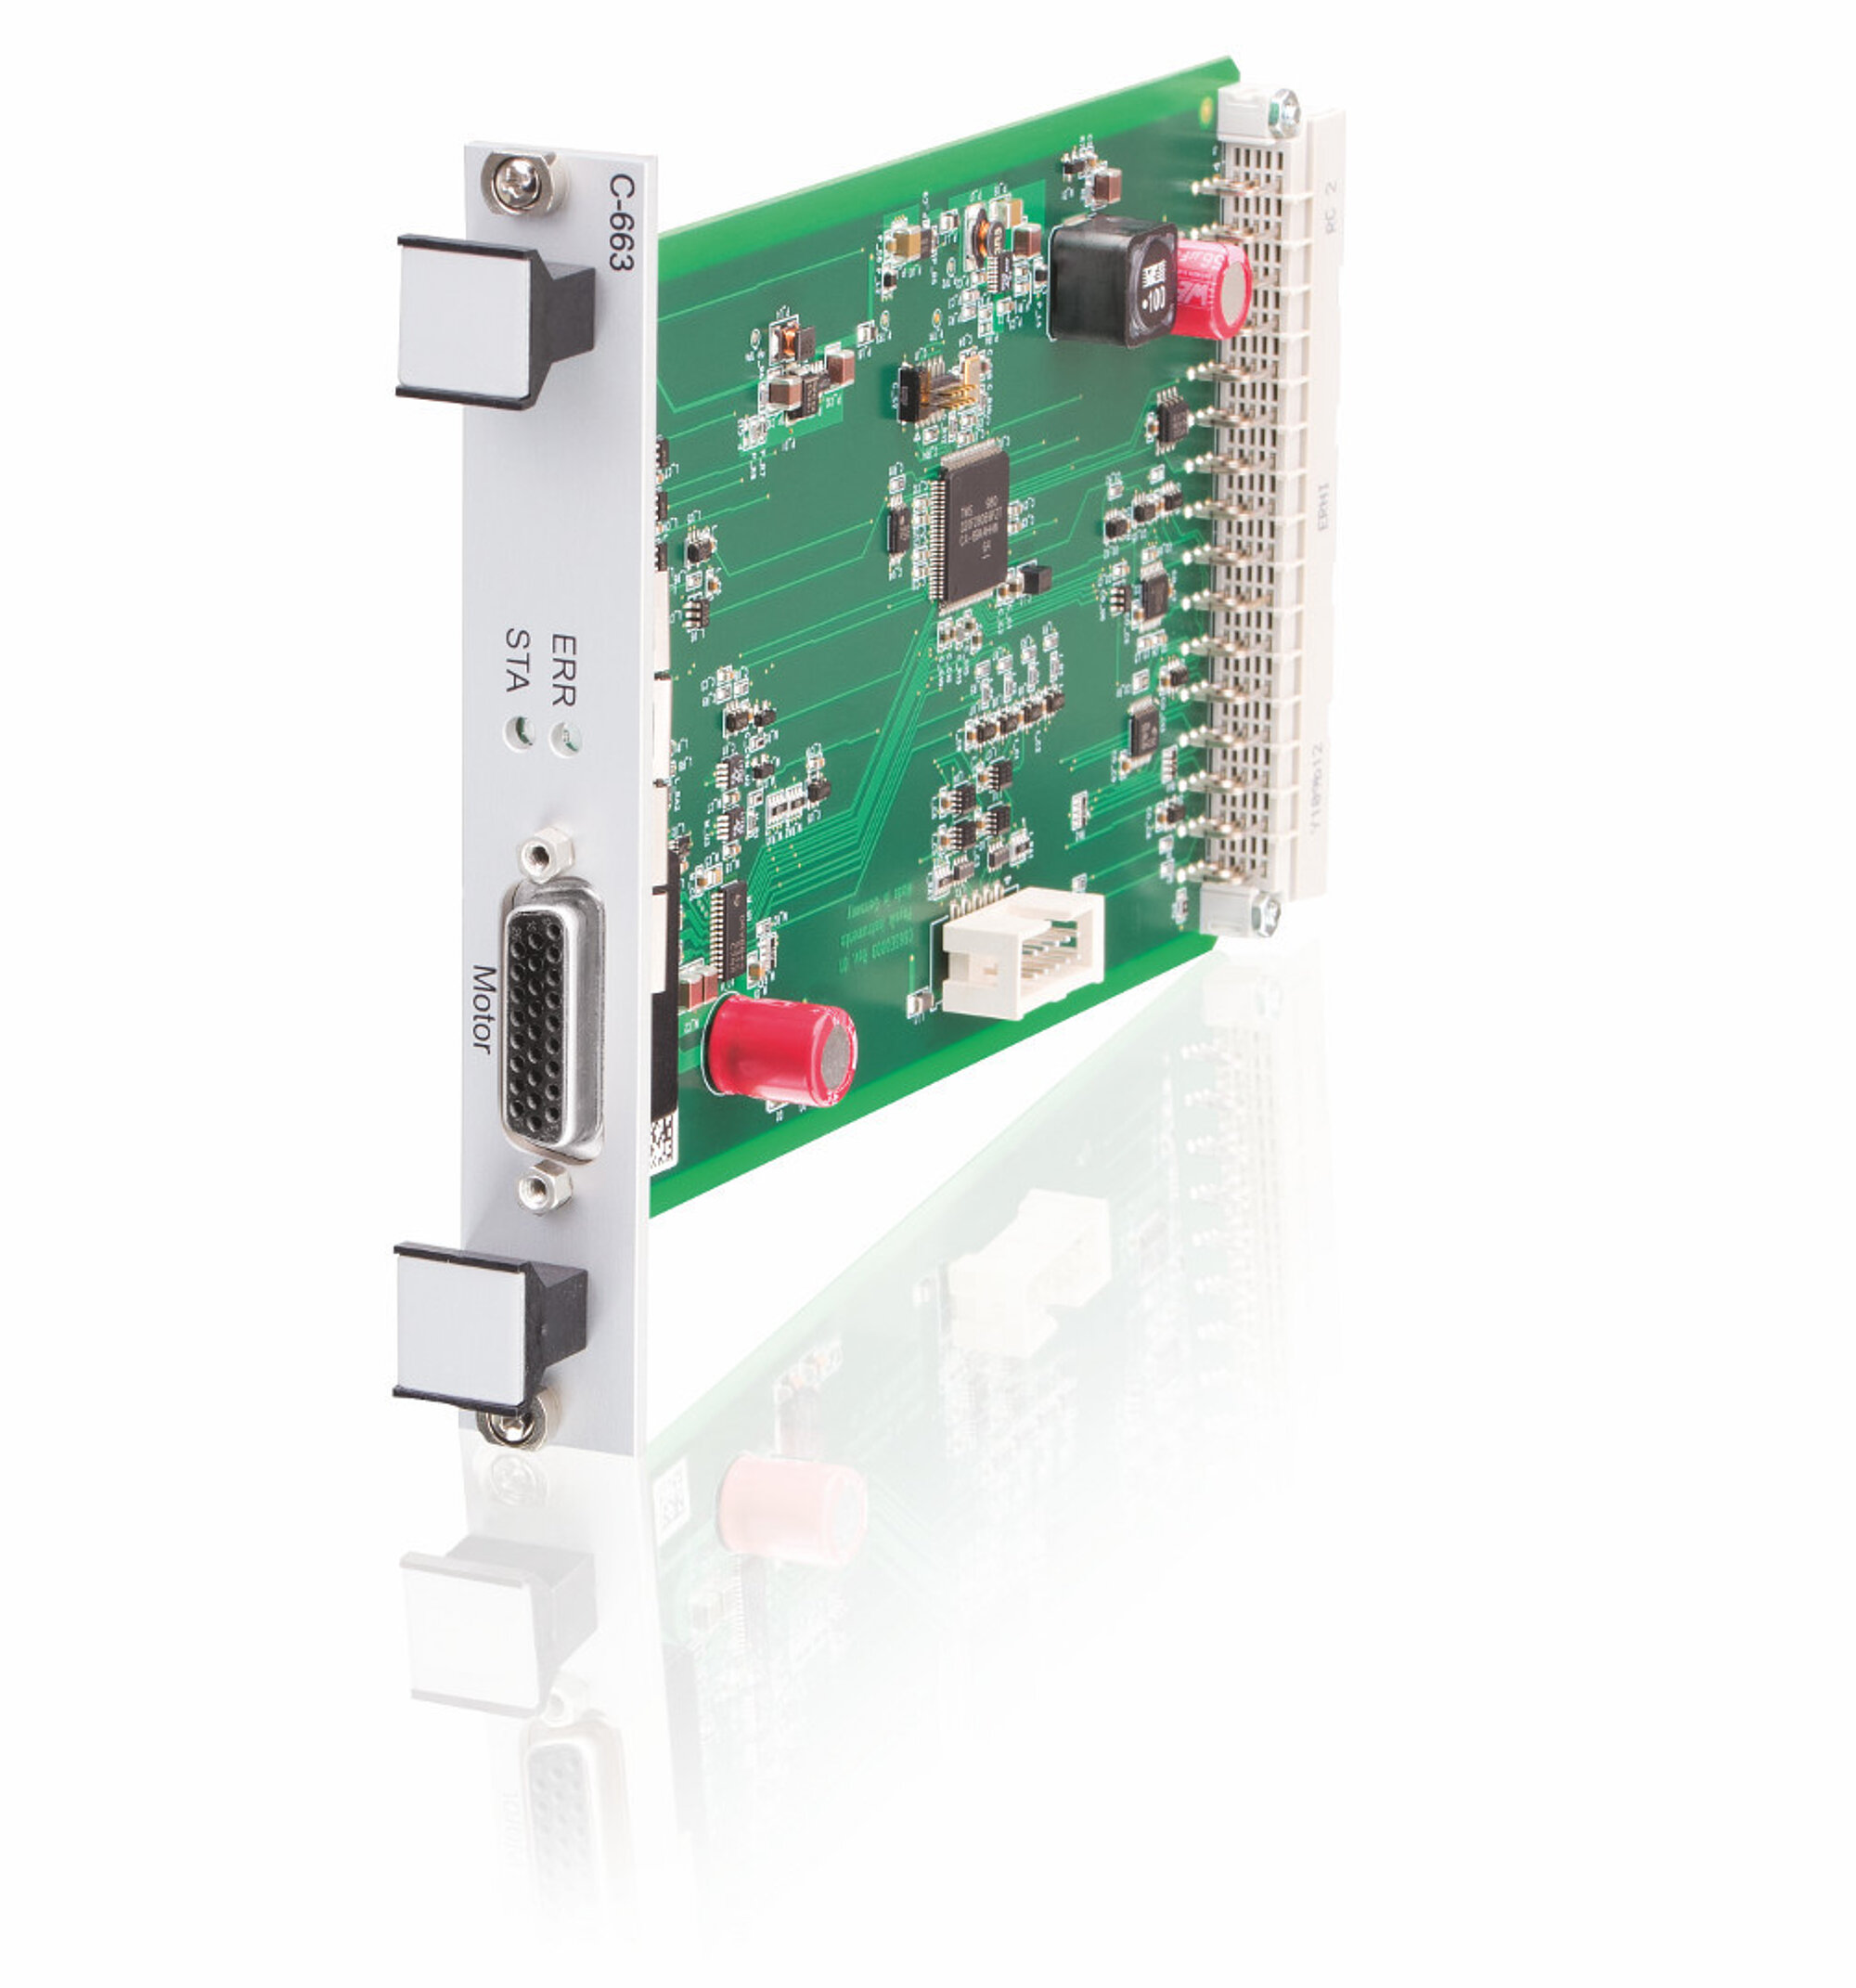
Mercury Step stepper motor controller module; 1 axis; closed-loop and open-loop operation, support for external sensors; for PIMotionMaster
C-663.12C885 Mercury Step Stepper Motor Controller Module for C-885 PIMotionMaster
For Positioners with 2-Phase Stepper Motors, 1 Axis
- High microstep resolution
- Fast-running motor (output voltage 48 V, even at lower operating voltage)
- Closed-loop operation of 2-phase stepper motors
- Support for external sensors
- ID chip detection for fast startup
Mercury Step controller module for positioners with 2-phase stepper motors
1 axis. Microstep resolution: 1/2048 full step. Closed-loop operation. Point-to-point motion, trapezoidal velocity profile. Fast-running motor, even at lower operating voltage.
Technology
Interfaces
Differential signal transmission for digital (A/B) encoder signals. Inputs for TTL signals for limit and reference switches. Input for RS-422 signals for index switch. I/O lines (analog / digital) for automation.
Functionality and software
Powerful macro programming language. Nonvolatile macro memory, e.g., for stand-alone operation with autostart macro. Data recorder. ID chip detection for fast startup. PID controller, parameters modifiable during operation.
Extensive software support, e.g., for NI LabVIEW, C, C++, MATLAB, Python. PIMikroMove user software.
Installation and operation
Plug-and-play installation in the C-885 PIMotionMaster: Can be inserted in any free slot. Automatic detection and external communication by the processor and interface module of the C-885. Expandable by optional digital inputs and outputs. Power supply via the power adapter of the C-885.
Specifications
Specifications
Basics | C-663.12C885 |
|---|---|
Housing type | Module without housing, 4 HP |
Drive type | 2-phase stepper motor |
Axes | 1 |
Application-related functions | Startup macro; data recorder; ID chip detection |
Protective functions | Automatic motor stop when a programmable position error is exceeded; temperature protection switches off at excessively high temperatures; internal safety circuitry: Watchdog timer |
Configuration management | Import of parameter files; manual parameter input; reading the ID chip (for future use) |
Interfaces and operation | C-663.12C885 |
|---|---|
Communication interfaces | TCP/IP; USB |
Command set | GCS 2.0 |
User software | PIMikroMove |
Application programming interfaces | C, C++, C#; MATLAB; NI LabVIEW; Python |
Analog inputs | 4 (optionally via C-885) |
Analog input signal | 0 V to 5 V |
Digital inputs | 4 (optionally via C-885) |
Digital input signal | TTL |
Digital outputs | 4 (optionally via C-885) |
Digital output signal | TTL |
* At lower supply voltages, the 48 V output voltage is generated by means of a voltage converter.
Downloads
データシート
ドキュメント
User Manual C663T0004
C-663.12C885 Motion Controller Module for Stepper Motors, for C-885 PIMotionMaster
User Manual MS241
C-663.12 Mercury Step Stepper Motor Controller
User Manual C663T0005
Parameter Handling when Upgrading to C-663.12 Controllers
一般的なソフトウェアのドキュメント
User Manual SM164
Updating controller firmware with PIFirmwareManager
Ask for a free quote on quantities required, prices, and lead times or describe your desired modification.